> ## Documentation Index
> Fetch the complete documentation index at: https://dragonwingdocs-staging.qualcomm.com/llms.txt
> Use this file to discover all available pages before exploring further.
# Run basic OCR with ocr_service
The `ocr_service` sample application enables a service that provides the Optical Character Recognition (OCR) function.
It captures the image topic from the ROS system and publishes the result with the `ocr_topic`.
## Pipeline flow for `ocr_service`
This figure shows the basic messages and data transfer channels, with the relevant client/server and ROS node.

Figure : ocr\_service pipeline
## ROS nodes used in the `ocr_service `pipeline
| ROS node | Description |
| :-: | :- |
| `OCR_CLIENT` | Sends the OCR request to `ocr_server` and gets the server result. |
| `OCR_SERVER` | Gets the OCR request from `ocr_server` , and forks the `ocr_rosnode` according to the request. |
| `OCR_ROSNODE` | Subscribes to the image topic according to the request. |
## ROS topics used in the `ocr_service `pipeline
| ROS topic |
Message type |
Published/Subscribed by |
Description |
| `/image_topic_name` |
`` |
Subscribe to images from other nodes |
The image to be processed. |
| `/ocr_image_topic_name` |
`` |
Published by `ocr-rosnode` |
Publishes the OCR result. |
## Prerequisites
You have **Set up the device** according to [Set up the environment for running sample applications](./set-up-env-for-sample-app).
## Run out-of-the-box `ocr_service`
Start three terminals, and run the following commands in each terminal.
Value range of `ROS_DOMAIN_ID`: \[0, 232]
```bash theme={null}
ssh root@[ip-addr]
```
```bash title="SSH Session" theme={null}
source /usr/share/qirp-setup.sh
export ROS_DOMAIN_ID=xx
```
In terminal 1, launch `ocr_server`.
```bash title="SSH Session" theme={null}
ros2 run ocr_service ocr_server
```
In terminal 2, push an image to the device and run the `ocr_testnode`.
```bash theme={null}
wget https://raw.githubusercontent.com/qualcomm-qrb-ros/ocr_service/stable/1.0.0/scripts/digital_720p.png -O digital_720p.png
scp digital_720p.png root@[ip-addr]:/opt
```
```bash title="SSH Session" theme={null}
ros2 run ocr_service ocr_testnode --topic imagetest --picture /opt/digital_720p.png
```
In terminal 3, run the `ocr_client`.
```bash title="SSH Session" theme={null}
ros2 run ocr_service ocr_client imagetest
```
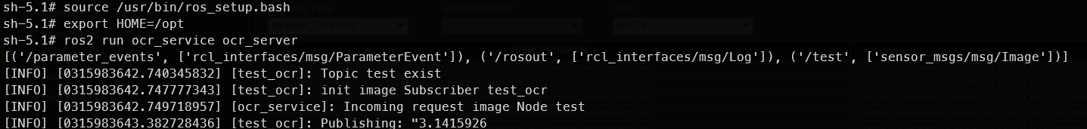
You will see the following log:
 ## Build and run `ocr_service`
```bash theme={null}
cd
source setup.sh
cd qirp-samples/platform/ocr_service
colcon build --merge-install --cmake-args ${CMAKE_ARGS}
```
```bash theme={null}
cd
cd qirp-samples/platform/ocr_service/install
tar -zcvf ocr_service.tar.gz lib/ share/
scp ocr_service.tar.gz root@[ip-addr]:/opt
ssh root@[ip-addr]
```
```bash title="SSH Session" theme={null}
tar --no-overwrite-dir --no-same-owner -zxf /opt/ocr_service.tar.gz -C /usr/ros/jazzy/
```
```bash theme={null}
wget https://raw.githubusercontent.com/qualcomm-qrb-ros/ocr_service/stable/1.0.0/scripts/digital_720p.png -O digital_720p.png
scp digital_720p.png root@[ip-addr]:/opt
```
Run `ocr_service` on the device with the steps in [Run out-of-the-box ocr\_service](#run-out-of-the-box-ocr_service).